RoboBoat 2026: Autonomous Surface Vehicle
Autonomous surface vehicle competing in the international RoboBoat challenge.
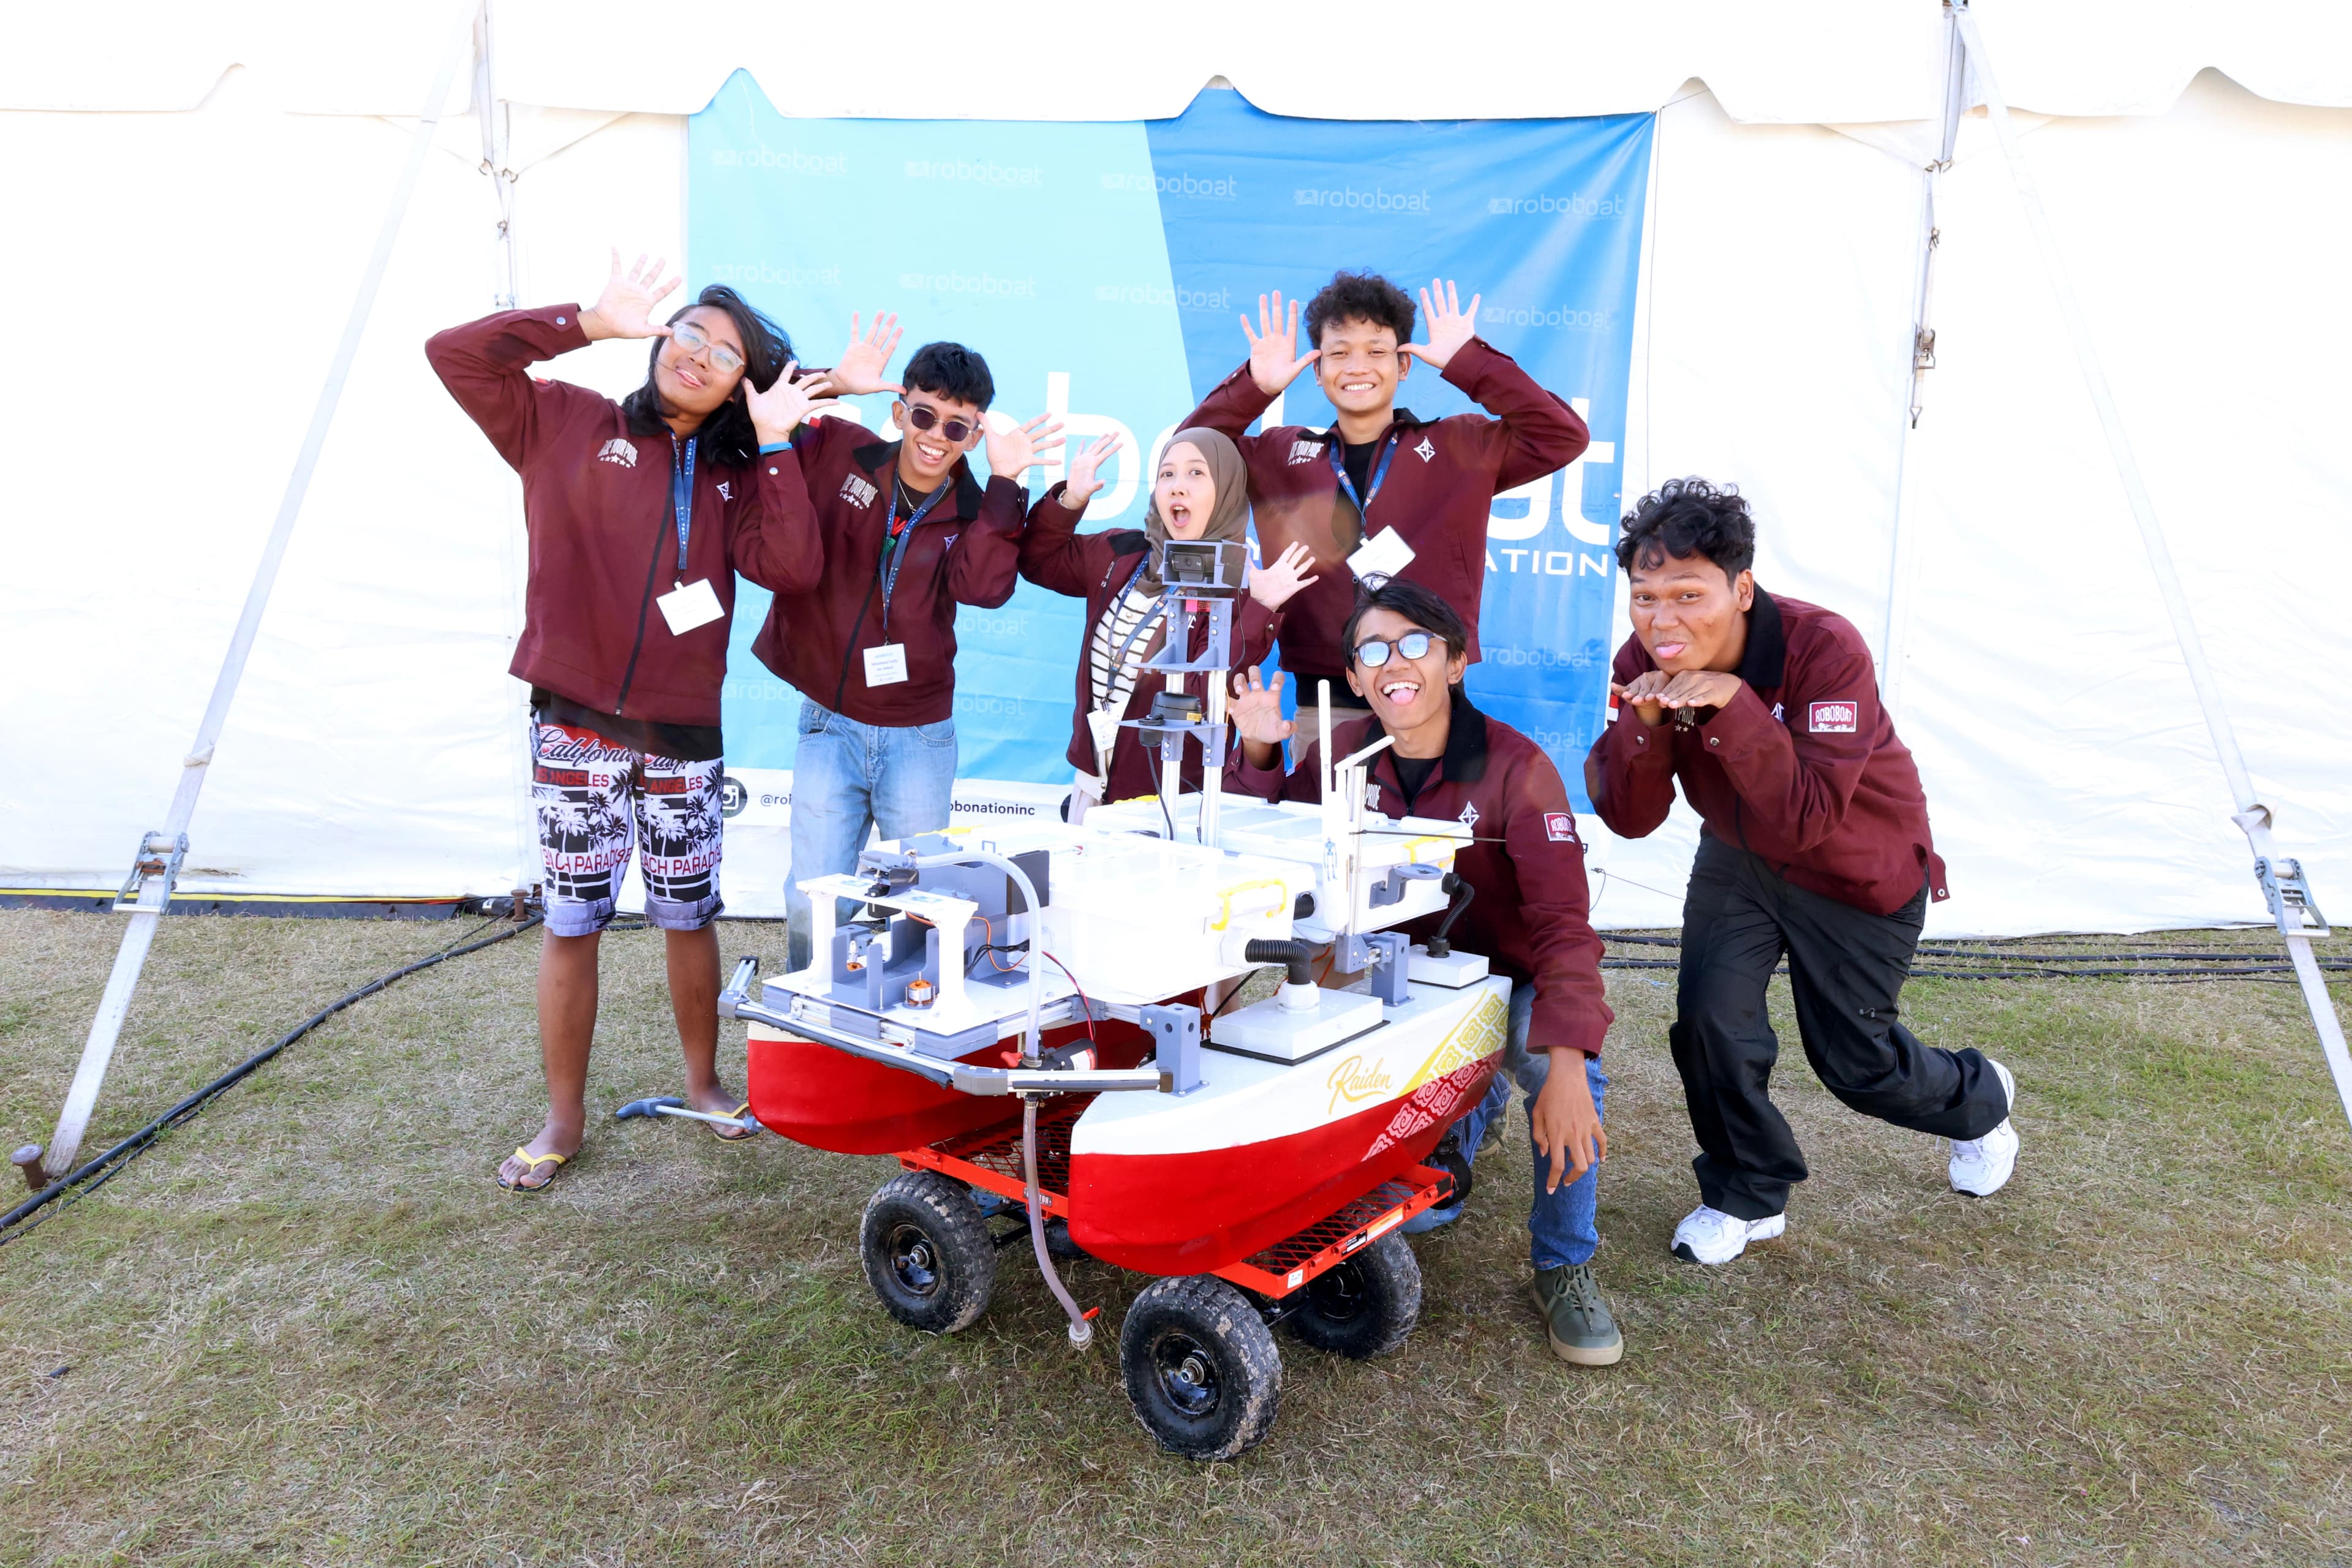
Mandakini Raiden is the autonomous surface vehicle built by the Bengawan UV team at Universitas Sebelas Maret for RoboBoat 2026, combining a Jetson Nano, camera, 2D LiDAR, RTK-GPS, and a Cube Orange flight controller into one system. The goal: make perception, navigation, and control work together reliably in real time, not just make the boat move.
Making camera, LiDAR, RTK-GPS, and the flight controller act as one system. Each mission (buoy navigation, obstacle avoidance, docking) had to stay reliable in real time on real water.
Built a ROS autonomy stack on a Jetson Nano: YOLOv4-Tiny + TensorRT for real-time detection, fused with LiDAR for spatial awareness and adaptive waypoints. RTK-GPS handles positioning, MAVROS bridges to the Cube Orange flight controller. Tested progressively from simulation to on-water trials.
def run_mission(camera, detector, handler, waypoint):
    """Steer toward the detected target; fall back to GPS when it's lost."""
    detection = detector.detect(camera.read())
    if detection:
        handler.set_velocity(speed=MISSION_SPEED, yaw_rate=steer_toward(detection))
    else:
        handler.move(*waypoint)